Norwegian version of this page

DEEPCOBOT Collective efficient deep learning and networked control for multiple collaborative robot systems

Duration
–
Project type
Research project

In recent years, collaborative robot systems have received a great deal of attention in the context of a large number of industrial applications, such as additive manufacturing, automotive manufacturing, material handling, packaging and co-packing and quality inspection. The collaboration between multiple collaborative robots and human operators is considered to be the most prominent strategy in Industry 4.0 and future Industry 5.0, sharing the same space and collaborating on tasks according to their complementary capabilities.

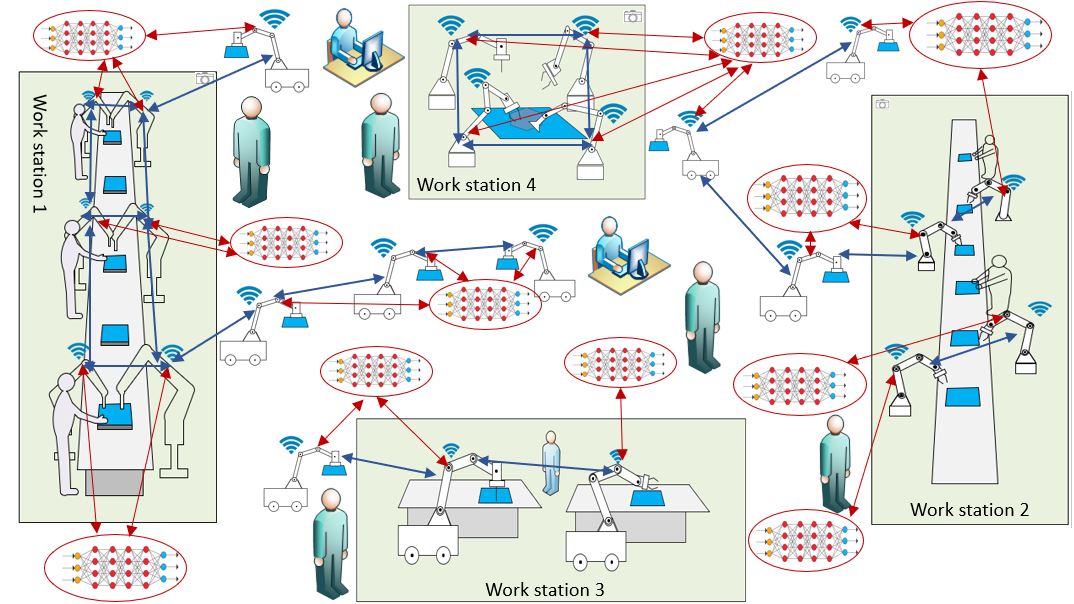
DEEPCOBOT illustrasjonsdiagram

Project description

DEEPCOBOT project will investigate the design of a new generation of decentralised data-driven Deep Learning based controllers for multiple coexisting collaborative robots (Cobot), which interact both between themselves and with human operators in order to collectively learn from each other's experiences and perform cooperatively different complex tasks in large-scale industrial environments. This is motivated by the increasing demand of automation in industry, especially the demand of a safer and more efficient collaboration between multiple Cobots and human operators to integrate the best of human abilities and robotic automation.

The vision of this project is that the learning of the optimal local control policies can be substantially accelerated by sharing both information about previous experiences and computation across multiple neighbour Cobots connected through a wireless communication network, providing solutions that satisfy the necessary real-time constraints in the considered robotic applications, as well as providing sufficient robustness and interchangeability to the control solutions.

This multidisciplinary project covers the areas of deep learning, optimisation, reinforcement learning, decentralised shared control, embodied Artificial Intelligence (intelligent robots and devices), bi-directional interaction between Cobots and human operators, and cross-layer networking with a significant potential in industrial applications.
Results

Read more on the project's webpage

Participants

Publications

  • Vinod, Dinsha & Zhou, Jing (2026). Adaptive Event-Triggered Control for Uncertain Polytopic NLPV Systems: An Application in Robotic Vision. IEEE transactions on industrial electronics (1982. Print). ISSN 0278-0046. 73(6), p. 9245–9255. doi: 10.1109/tie.2026.3651341. Full text in Research Archive
  • Østerholt, Lars; Gundersen, Are; Zhou, Jing & Hagen, Daniel (2025). Real-Time Markerless Vision-Based Control of Knuckle Boom Cranes via Embedded AI. International Conference on Control, Mechatronics and Automation. ISSN 2837-5114. 2025. doi: 10.1109/iccma67641.2025.11369496. Full text in Research Archive
  • Vinod, Dinsha & Zhou, Jing (2025). Adaptive event-triggered control for resource-based auto-scaling of an uncertain distributed fog computing platform. Proceedings of the Annual Conference of the IEEE Industrial Electronics Society (IECON). ISSN 1553-572X. doi: 10.1109/iecon58223.2025.11221340. Full text in Research Archive
  • Zhu, Mingda; Eidsvik, Johannes Arnesen; Landsverk, Ronny; Hagen, Daniel & Zhou, Jing (2025). Rapid Model-Based Design and Real-Time Digital Twin Integration: An Offshore Robot Case Study. Proceedings of the IEEE International Symposium on Industrial Electronics. p. 1–6. doi: 10.1109/isie62713.2025.11124748. Full text in Research Archive
  • Zhu, Mingda; Han, Peihua; Landsverk, Ronny; Strandene, Jan Christian Bjerke; Hagen, Daniel & Zhou, Jing (2025). A Data-driven Approach to Payload Heave Motion Prediction under Irregular Waves, IEEE Industrial Electronics Society Annual On-Line Conference (ONCON). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9798350357981. doi: 10.1109/ONCON62778.2024.10931669. Full text in Research Archive
  • Schlanbusch, Siri Marte; Zhou, Jing & Schlanbusch, Rune (2025). Quantized Predictor-Based Tracking Control for Input Delay Systems: Application to a Helicopter System. IEEE Conference on Decision and Control. Proceedings. ISSN 0743-1546. doi: https:/ieeexplore.ieee.org/document/10886553. Full text in Research Archive
  • Zhu, Mingda; Nguyen, Hoang Nam Du; Han, Peihua; Zhou, Jing & Huynh, van Khang (2025). A Semi-Supervised Variational Autoencoder for Fault Detection of Low-Severity Inter-Turn Short-Circuit in PMSMs, 2025 IEEE Workshop on Electrical Machines Design, Control and Diagnosis - WEMDCD. IEEE (Institute of Electrical and Electronics Engineers). ISSN 9798331520748. doi: 10.1109/WEMDCD61816.2025.11014178. Full text in Research Archive
  • Sveen, Emil Mühlbradt; Zhou, Jing; Ebbesen, Morten Kjeld & Poursina, Mohammad (2025). Decentralised adaptive learning-based control of robot manipulators with unknown parameters. Journal of Automation and Intelligence (JAI). 4(2), p. 136–144. doi: 10.1016/j.jai.2025.02.002. Full text in Research Archive
  • Vinod, Dinsha & Zhou, Jing (2025). Event-Based Control for Discrete Polytopic LPV Systems With AI Inference. IEEE transactions on industrial electronics (1982. Print). ISSN 0278-0046. 72(9), p. 9497–9507. doi: 10.1109/TIE.2025.3536560. Full text in Research Archive
  • Nama, Ajay Nagendra; Beferull-Lozano, Baltasar; Saad, Leila Ben & Zhou, Jing (2024). Node-Variant Graph Filter Based Multi-Agent Deep Reinforcement Learning for Aligned Game and Wireless Environments. IEEE Conference on Industrial Electronics and Applications. 19. doi: 10.1109/ICIEA61579.2024.10665191. Full text in Research Archive
  • Sveen, Emil Mühlbradt & Zhou, Jing (2024). Learning Based Adaptive Dynamic Programming of a Four-Bar Mechanism with Linear Approximation. IEEE Conference on Industrial Electronics and Applications. doi: 10.1109/ICIEA61579.2024.10665201. Full text in Research Archive
  • Singh, Jayant; Zhou, Jing; Beferull-Lozano, Baltasar; Yan, Shijun & Khan, Shalman (2024). Haptic Teleoperation Framework for Learning Task Space Fine Manipulation Skills. IEEE Conference on Industrial Electronics and Applications. doi: 10.1109/ICIEA61579.2024.10665270. Full text in Research Archive
  • Vinod, Dinsha & Zhou, Jing (2024). An event-triggered MPC scheme for discrete pLPV systems: Application in auto-scaling of compute nodes in a fog cluster. Proceedings of the Annual Conference of the IEEE Industrial Electronics Society (IECON). ISSN 1553-572X. p. 1–6. doi: https:/ieeexplore.ieee.org/document/10906025. Full text in Research Archive

View all works in NVA

View all works in NVA

  • Wathne, Joakim Holtskog; Hansen, Michael Rygaard & Zhou, Jing (2025). Benefits of Secondary Control over Primary Control for AHC Winches. Full text in Research Archive
  • Zhou, Jing (2025). Data-driven control and applications. doi: https:/irce.org/2025.html. Full text in Research Archive
  • Zhou, Jing (2025). Adaptive Control with Quantization. doi: https:/ecc25.euca-ecc.org/. Full text in Research Archive
  • Zhou, Jing (2025). Data-Driven Adaptive and Quantized Control - Theory and Applications. doi: https:/ieeexplore.ieee.org/xpl/conhome/1835066/all-proceedings. Full text in Research Archive
  • Hagen, Daniel (2025). Rapid Model-Based Design and Real-Time Digital Twin Integration: An Offshore Robot Case Study. doi: 10.1109/isie62713.2025.11124748. Full text in Research Archive
  • Gaustad, Eskil Gresen; Knausgård, Kristian Muri & Zhou, Jing (2025). Supervisory Control Design for a SES Vessel. Universitetet i Agder. Full text in Research Archive

View all works in NVA

Funding

Funded by The Research Council of Norway

Project number: 306640

Published May 2, 2024 8:20 AM - Last modified Aug. 8, 2025 11:04 AM