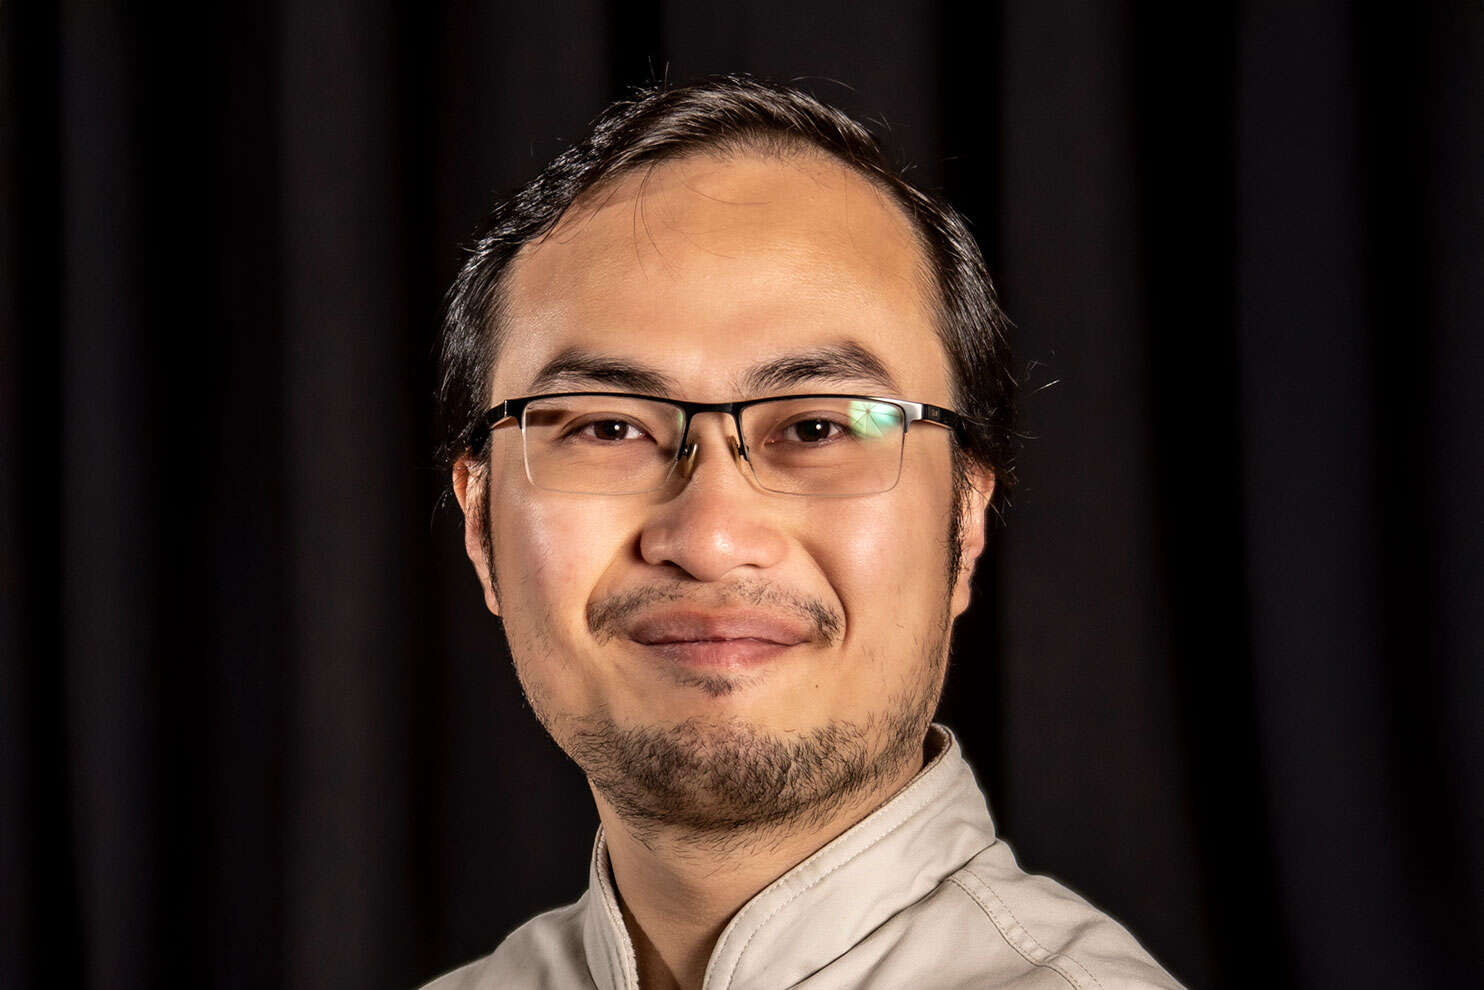
Minh Tuan Hua has followed the PhD Programme at Faculty of Engineering and Science, Specialisation in Mechatronics.
- Trial lecture starts at 10.15
- Public defence starts at 12.15
Title of trial lecture: "Consequences and counter measures related to flexible bodies and joints in practical use of robots"
Disputation chair: Paul Ragnar Svennevig
Assessment committee:
- First opponent: Professor Bruno Siciliano, DIETI, University of Naples Federico II, Italy
- Second opponent: Associate Professor Monica Malvezzi, University of Siena, Italy
- Chair of assessment committee: Associate Professor Morten Kjeld Ebbesen, UiA
Supervisor in the doctoral work:
- Main supervisor: Professor Filippo Sanfilippo, UiA
Summary of thesis
To make industrial and assistance robots safe enough to work alongside humans without protective cages, new research introduces a hybrid robotic arm that combines the speed and accuracy of traditional rigid joints with the forgiving, impact-absorbing qualities of flexible elastic joints. By building a six-joint arm—rigid at the base for strength and elastic at the wrist for safety—and equipping it with custom "yield-on-contact" control software, the robot can perform precise tasks while automatically softening its touch if an unexpected collision occurs. Validated through a 3D-printed physical prototype, this approach provides a safer, practical foundation for deploying collaborative robots in factories, hospitals, and homes.
What to do as an online audience member
The disputation is open to the public. To follow the trial lecture and the public defence online, register on Zoom.
We ask online audience members to join no earlier than 10 minutes in advance. After these times, you can leave and rejoin the meeting at any time.
Opponent ex auditorio:
Deadline for the public to pose questions is during the break between the two opponents. Questions ex auditorio can be submitted to Kristine Evensen Reinfjord.
Contact person

- kristine.reinfjord@uia.no
- Phone
- +47 37 23 30 14