Norwegian version of this page

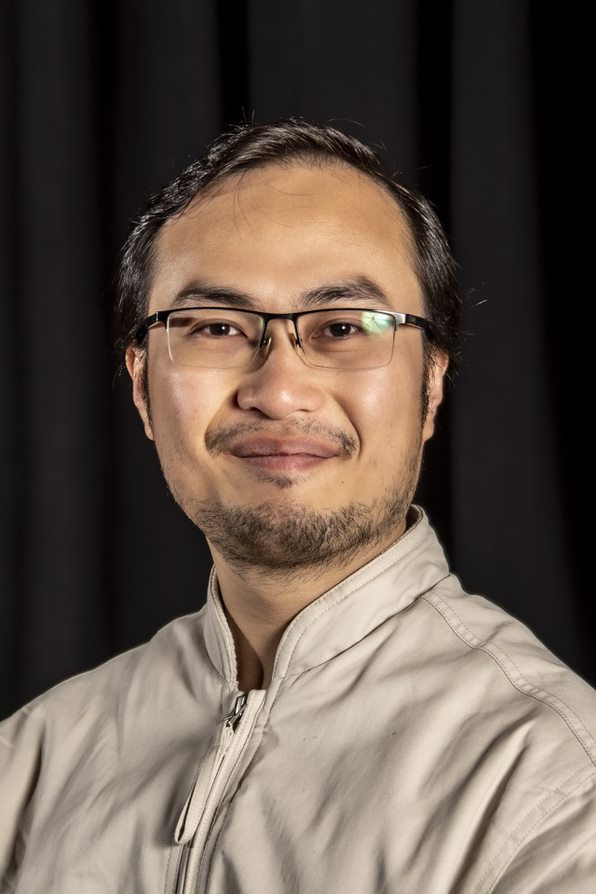
Minh Tuan Hua

Image of Minh Tuan Hua
Email
minh.tuan.hua@uia.no
Phone
+47 37 23 37 18
Office
D3063 (Jon Lilletuns vei 9, 4879 Grimstad, Norway)

Background and experience

Minh Tuan Hua (Graduate Student Member, IEEE) received the Bachelor of Engineering and Master of Engineering degrees in Control Engineering and Automation from Ho Chi Minh City University of Technology, Ho Chi Minh City, Vietnam, in 2017 and 2022, respectively. He is a PhD fellow at the University of Agder, Grimstad, Norway.  His research interests include adaptive, robust, and nonlinear control, modelling and identification, robot dynamics, and electronics.

Research

His research interests include robotics, and control theory (especially adaptive, robust, and nonlinear control theories), modelling and identification, robot dynamics, and electronics.

Publications

  • Hua, Minh Tuan; Poursina, Mohammad; Vu, Viet Hung & Sanfilippo, Filippo (2026). Dynamic Modeling and Analysis of Robotic Manipulators With Mixed Rigid–Elastic Joints. IEEE Access. 14, p. 33966–33995. doi: 10.1109/ACCESS.2026.3668125. Full text in Research Archive
  • Hua, Minh Tuan; Gravdahl, Jan Tommy & Sanfilippo, Filippo (2025). Adaptive Cartesian Position Control with a Switching Strategy for Robotic Manipulator with Mixed Rigid-Elastic Joints. Proceedings of IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). ISSN 2153-0858. 2025, p. 7398–7405. doi: 10.1109/iros60139.2025.11247250. Full text in Research Archive
  • Hua, Minh Tuan; Gravdahl, Jan Tommy & Sanfilippo, Filippo (2025). Impedance Control for Robots with Mixed Rigid-Elastic Joints Using Sliding Mode Control. In IEEE (Eds.), 2025 European Control Conference (ECC). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9783907144121. p. 2914–2920. doi: 10.23919/ecc65951.2025.11187019. Full text in Research Archive
  • Sanfilippo, Filippo; Tataru, Marius; Hua, Minh Tuan; Johansson, Inge Johan Straumsøy & Andone, Diana (2025). Gamifying Cultural Immersion: Virtual Reality (VR) and Mixed Reality (MR) in City Heritage. IEEE Transactions on Games (TG). ISSN 2475-1502. 17(4), p. 893–911. doi: 10.1109/TG.2025.3553712. Full text in Research Archive
  • Sanfilippo, Filippo; Salvietti, Gionata; Blažauskas, Tomas; Gabriele, Guido; Zafar, Maria & Hua, Minh Tuan [Show all 14 contributors for this article] (2025). Integrating VR, AR, and Haptics in Basic Surgical Skills Training: A Review and Perspective. IEEE Access. 13, p. 99203–99220. doi: 10.1109/ACCESS.2025.3574265. Full text in Research Archive
  • Hua, Minh Tuan; Sveen, Emil Mühlbradt; Schlanbusch, Siri Marte & Sanfilippo, Filippo (2024). Robust-Adaptive Two-Loop Control for Robots with Mixed Rigid-Elastic Joints. In NN, . (Eds.), International Conference on Intelligent Robots and Systems (IROS). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9798350377705. p. 11332–11339. doi: 10.1109/IROS58592.2024.10802178. Full text in Research Archive
  • Hua, Minh Tuan; Park, Jong Hyeon & Sanfilippo, Filippo (2024). Modelling and Control of a Hybrid Robotic Arm with Mixed Rigid-Elastic Joints, 2024 IEEE 19th Conference on Industrial Electronics and Applications (ICIEA). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9798350360868. doi: 10.1109/ICIEA61579.2024.10665130. Full text in Research Archive
  • Sanfilippo, Filippo; Økter, Martin Bjaadal; Dale, Jørgen; Hua, Minh Tuan & Ottestad, Morten (2024). Revolutionising Prosthetics and Orthotics with Affordable Customisable Open-Source Elastic Actuators. In NN, . (Eds.), International Conference on Automation, Robotics and Applications (ICARA). Institute of Electrical and Electronics Engineers (IEEE). ISSN 9798350394252. p. 57–63. doi: 10.1109/ICARA60736.2024.10553120. Full text in Research Archive
  • Sanfilippo, Filippo; Økter, Martin Bjaadal; Dale, Jørgen; Hua, Minh Tuan; Zafar, Muhammad Hamza & Ottestad, Morten (2024). Open-source design of low-cost sensorised elastic actuators for collaborative prosthetics and orthotics. HardwareX. 19. doi: 10.1016/j.ohx.2024.e00564. Full text in Research Archive
  • Hua, Minh Tuan; Poursina, Mohammad & Sanfilippo, Filippo (2024). Dynamic Modelling of Mixed Rigid-Flexible Joint Robotic Manipulator Using Recursive Newton-Euler Formulation, 2024 10th International Conference on Automation, Robotics and Applications (ICARA). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9798350394245. p. 165–171. doi: 10.1109/ICARA60736.2024.10553136. Full text in Research Archive
  • Hua, Tuan; Langås, Even Falkenberg; Zafar, Muhammad Hamza & Sanfilippo, Filippo (2023). From rigid to hybrid/soft robots: Exploration of ethical and philosophical aspects in shifting from caged robots to human-robot teaming. In Yu, Wen (Eds.), 2023 IEEE Symposium Series on Computational Intelligence (SSCI). IEEE (Institute of Electrical and Electronics Engineers). ISSN 9781665430654. p. 1794–1799. doi: 10.1109/SSCI52147.2023.10372032. Full text in Research Archive
  • Hua, Tuan; Sanfilippo, Filippo & Hao, Nguyen Vinh (2022). A Novel Adaptive Sliding Mode Controller for a 2-DOF Elastic Robotic Arm. Robotics. 11(2). doi: 10.3390/robotics11020047. Full text in Research Archive
  • Sanfilippo, Filippo; Hua, Tuan Minh & Bos, Steven (2020). A comparison between a two feedback control loop and a reinforcement learning algorithm for compliant low-cost series elastic actuators. In Bui, Tung X. (Eds.), Proceeding of the 53rd Hawaii International Conference on System Sciences (HICSS 2020). AIS Electronic Library University of Hawai'i at Manoa Hamilton Library 2550 McCarthy Mall Honolulu, HI 96822. ISSN 9780998133133. p. 881–890. doi: 10.24251/hicss.2020.110. Full text in Research Archive
  • Hua, Tuan; Sanfilippo, Filippo & Helgerud, Erlend (2019). A robust two-feedback loops position control algorithm for compliant low-cost series elastic actuators. IEEE International Conference on Systems, Man, and Cybernetics (SMC). ISSN 2163-9590. p. 2384–2390. doi: 10.1109/SMC.2019.8913845. Full text in Research Archive

View all works in NVA

  • Hua, Tuan; Sanfilippo, Filippo & Hao, Nguyen Vinh (2021). An Adaptive Sliding Mode Controller for a 2-DOF Elastic Robotic Arm. Full text in Research Archive
  • Sanfilippo, Filippo; Hua, Tuan & Bos, Steven (2020). A comparison between a two feedback control loop and a reinforcement learning algorithm for compliant low-cost series elastic actuators. Full text in Research Archive
  • Hua, Minh Tuan (2026). Modelling and Control of Robotic Manipulators with Mixed Rigid- Elastic Joints. Universitetet i Agder. ISSN 9788284273327. Full text in Research Archive

View all works in NVA

Published Apr. 16, 2024 10:51 AM - Last modified May 28, 2024 9:02 PM